
Team Details
Lund Formula Student
| University | Lund University
SE Lund U short 169 |
|---|---|
| Location | Lund, Sweden |
| Homepage | https://www.lundformulastudent.se |
| Social Media | |
| CV Team | Lund Formula Student |
| DV Team | Lund Formula Student |
| Short Link | tid.fsg.one/1049 |
Team Description
Lund Formula Student was previously known as LU Racing and has been building racing cars since 2006.
Past Events
2026
Info
169x
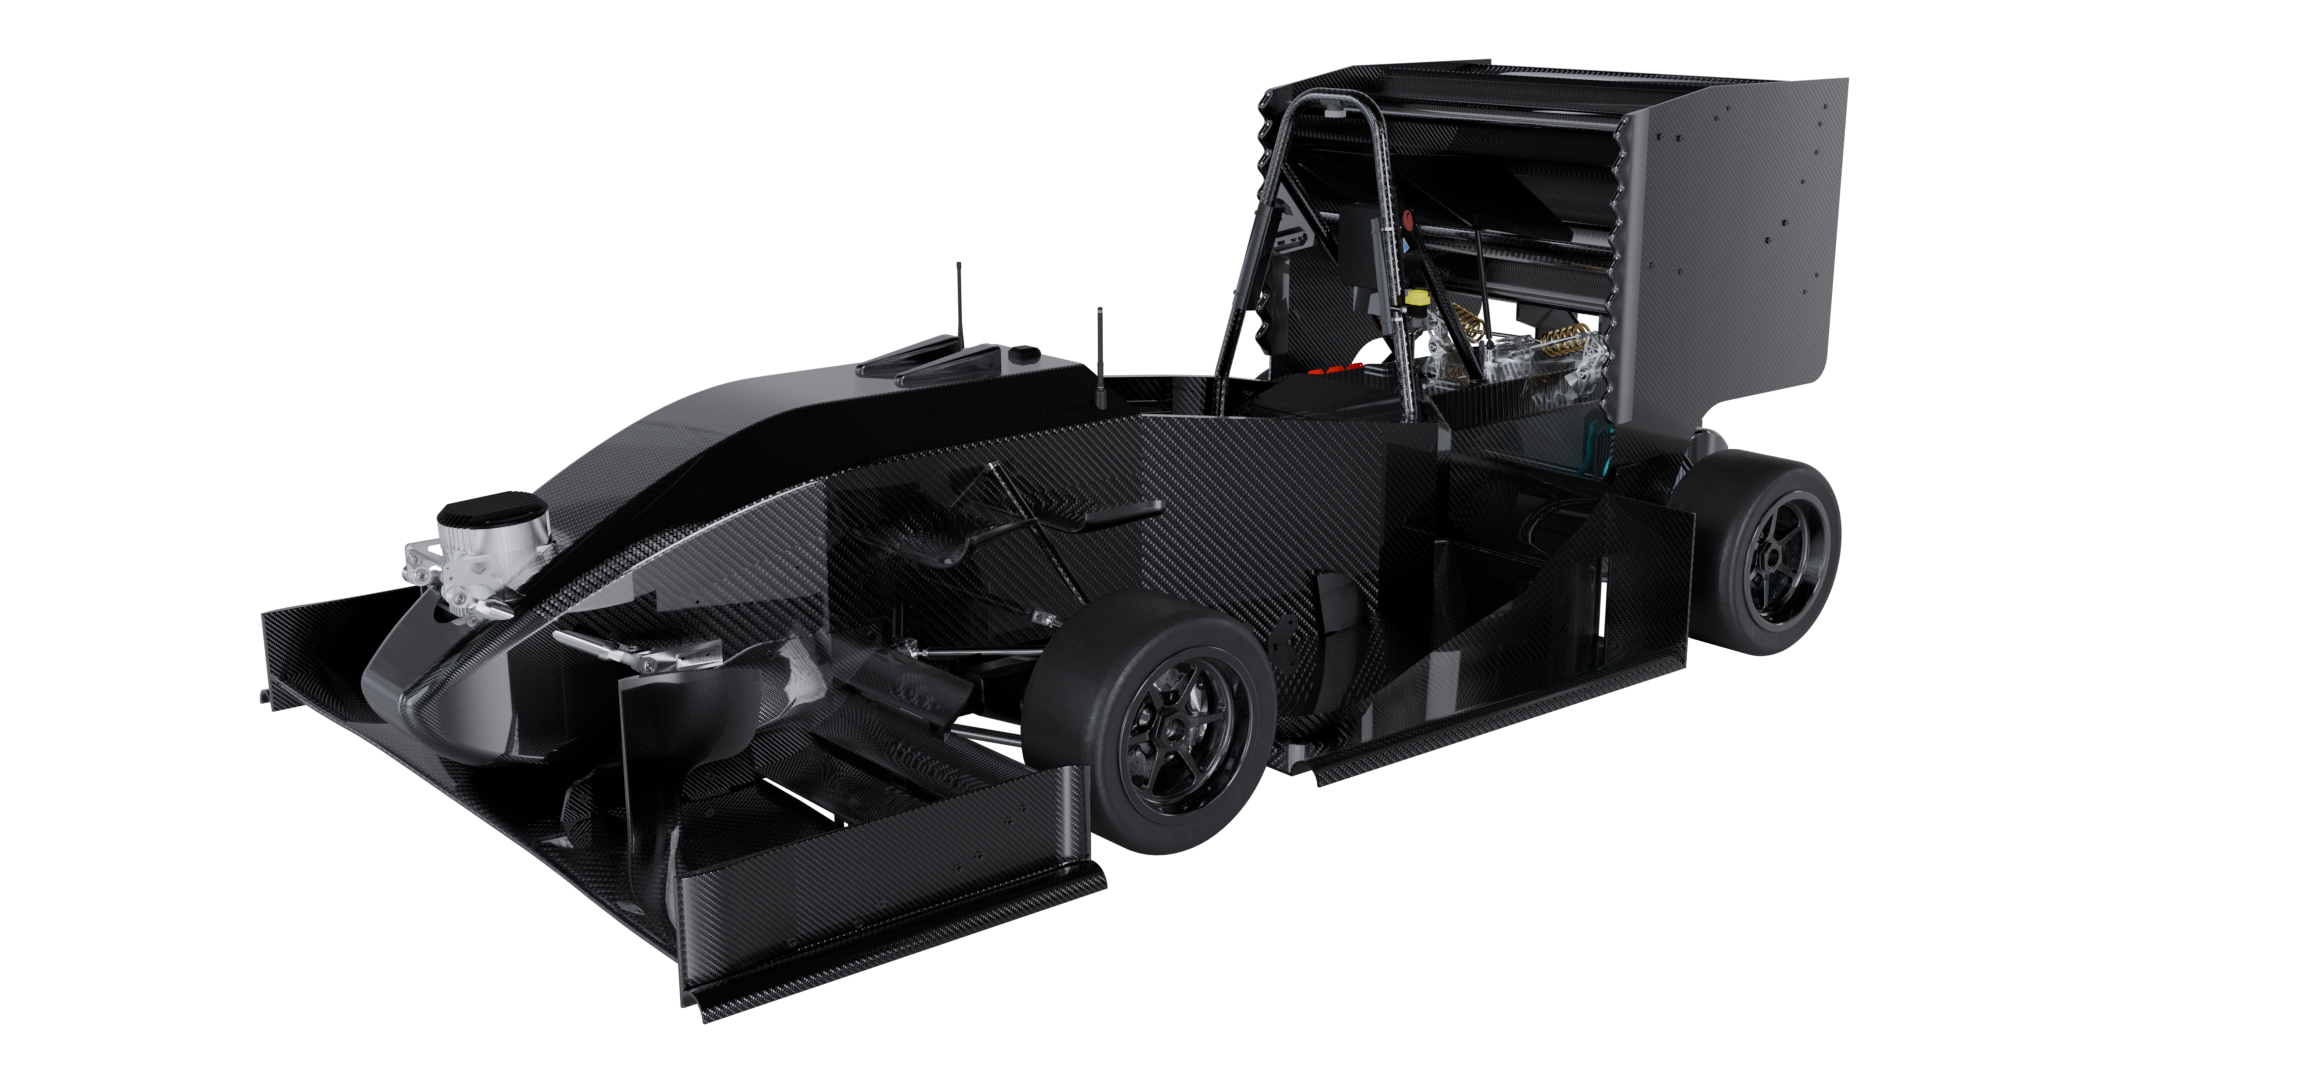
From the south of Sweden, Lund Formula Student brings together coffee, carbon fibre and crazy ideas to build a race car from scratch. Representing Lund University, we celebrate 20 years of team history with our biggest technical step yet: a new hub-motor AWD concept, developed alongside autonomous functionality to push both our car and our team forward.
Engineering Design Priorities:
Reliability - Working car
Manufacturability - Good
Performance - Fast car
Autonomous - Lighter car
Controls - Handling car
Innovation - Creative car
Car Specifications
General
| Frame Construction | CFRP monocoque |
|---|---|
| Material | Aluminium honeycomb core with T700 & T300 fibres |
| Overall L | 2855 mm |
| Overall W | 1608 mm |
| Overall H | 1048 mm |
| Wheelbase | 1535 mm |
| Track (Fr) | 1250 mm |
| Track (Rr) | 1250 mm |
| Weight with 68kg driver (Fr) | 119 kg |
| Weight with 68kg driver (Rr) | 144 kg |
| Suspension | Double A-Arm, pushrod w/ Öhlins TTX25 MkII 4-way adjustable corner dampers, 1 ARB/axle |
| Tyres (Fr / Rr) | Hoosier 16x7.5-10” R20 |
| Wheels (Fr / Rr) | 7x10 OZ Formula Student Hybrid Carbon CL, 22 mm offset |
| Drive Type | Direct |
| Differential | - |
| Cooling | Watercooled inverters, aircooled front motors, watercooled rear motors |
| Brake System | Dual circuit w/ adjustable front-rear bias, drilled, floating discs. Fr 180 mm, Rr 180 mm |
| Electronics | Wireharness w/ isolated CAN comm., LED dashboard, custom live telemetry & data logger |
Powertrain
| Number of Motors | 4 |
|---|---|
| Motor Location | FR, FL, RR, RL |
| Max Motor Power (per motor) | 35 kW |
| Motor Type | DTI F-MOT (all) |
| Max Motor RPM (highest) | 20000 rpm |
| Motor Controller | DTI F-SIC |
| Max System Voltage | 616 V |
| Electrode Materials | NMC532 - graphite |
| Combined Accumulator Capacity | 7.07 kWh |
| Transmission Ratio (Primary) | 13.48 : 1 |
| Transmission Ratio (Secondary) | - |
Driverless System
| Processing unit(s) | SAMC21G18A, STM32H723GZ, Intel 12700K with 32 GB RAM |
|---|---|
| Floating Point Operations Per Second of all processing units that are working for the DV system | 1300 GigaFLOPS |
| Power consumption of all processing units that are working for the DV system | 60 W |
| Camera(s) | - |
| Radar sensor(s) | - |
| Lidar sensor(s) | 1x Hesai 40P, 360 deg horizontal FOV, 40 channels |
| Other sensors | - |
| Highlights of the DV system | LiDAR-based localization, model predictive control, extensive validation on high-speed test data. |
FS past achievements due to World Ranking Data Base
| Date | Event | Teams | Rank | BP | CM | ED | SP | DV SP | AC | DV AC | AX | EN | EF | Pe | Total |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 2026.08 | 80 |
26. |
24. |
12. |
36. |
44. |
17. |
39. |
18. |
33. |
- |
- |
0.00 |
356.39 |
|
| 2026.07 | 52 |
28. |
36. |
37. |
38. |
17. |
- |
- |
- |
23. |
- |
- |
-10.00 |
191.04 |
|
| 2025.08 | 53 |
18. |
34. |
11. |
26. |
15. |
- |
29. |
- |
19. |
15. |
13. |
0.00 |
388.15 |
|
| 2025.07 | 44 |
15. |
9. |
9. |
11. |
15. |
- |
- |
- |
14. |
- |
- |
-20.00 |
281.49 |
|
| 2024.08 | 47 |
9. |
13. |
13. |
26. |
18. |
- |
19. |
- |
10. |
9. |
11. |
0.00 |
494.20 |
|
| 2024.07 | 31 |
14. |
3. |
25. |
16. |
11. |
- |
11. |
- |
10. |
- |
- |
-10.00 |
243.98 |
|
| 2023.08 | 31 |
10. |
9. |
22. |
23. |
13. |
- |
14. |
- |
10. |
8. |
8. |
0.00 |
474.79 |
|
| 2023.07 | 33 |
9. |
11. |
22. |
24. |
- |
- |
- |
- |
- |
3. |
3. |
0.00 |
321.45 |
|
| 2022.08 | 25 |
18. |
23. |
10. |
13. |
- |
- |
19. |
- |
13. |
- |
- |
-50.00 |
186.30 |
|
| x 9 | |||||||||||||||